TI mmWave 3D Tracking
IWR6843 · DSS, UART, Visualizer
mmWave Radar · Embedded Integration · System Validation
IWR6843 configuration, C674x DSS, and dual-UART integration for 3D people tracking, with hardware and Visualizer screens.
Hardware, runtime screens, and configuration records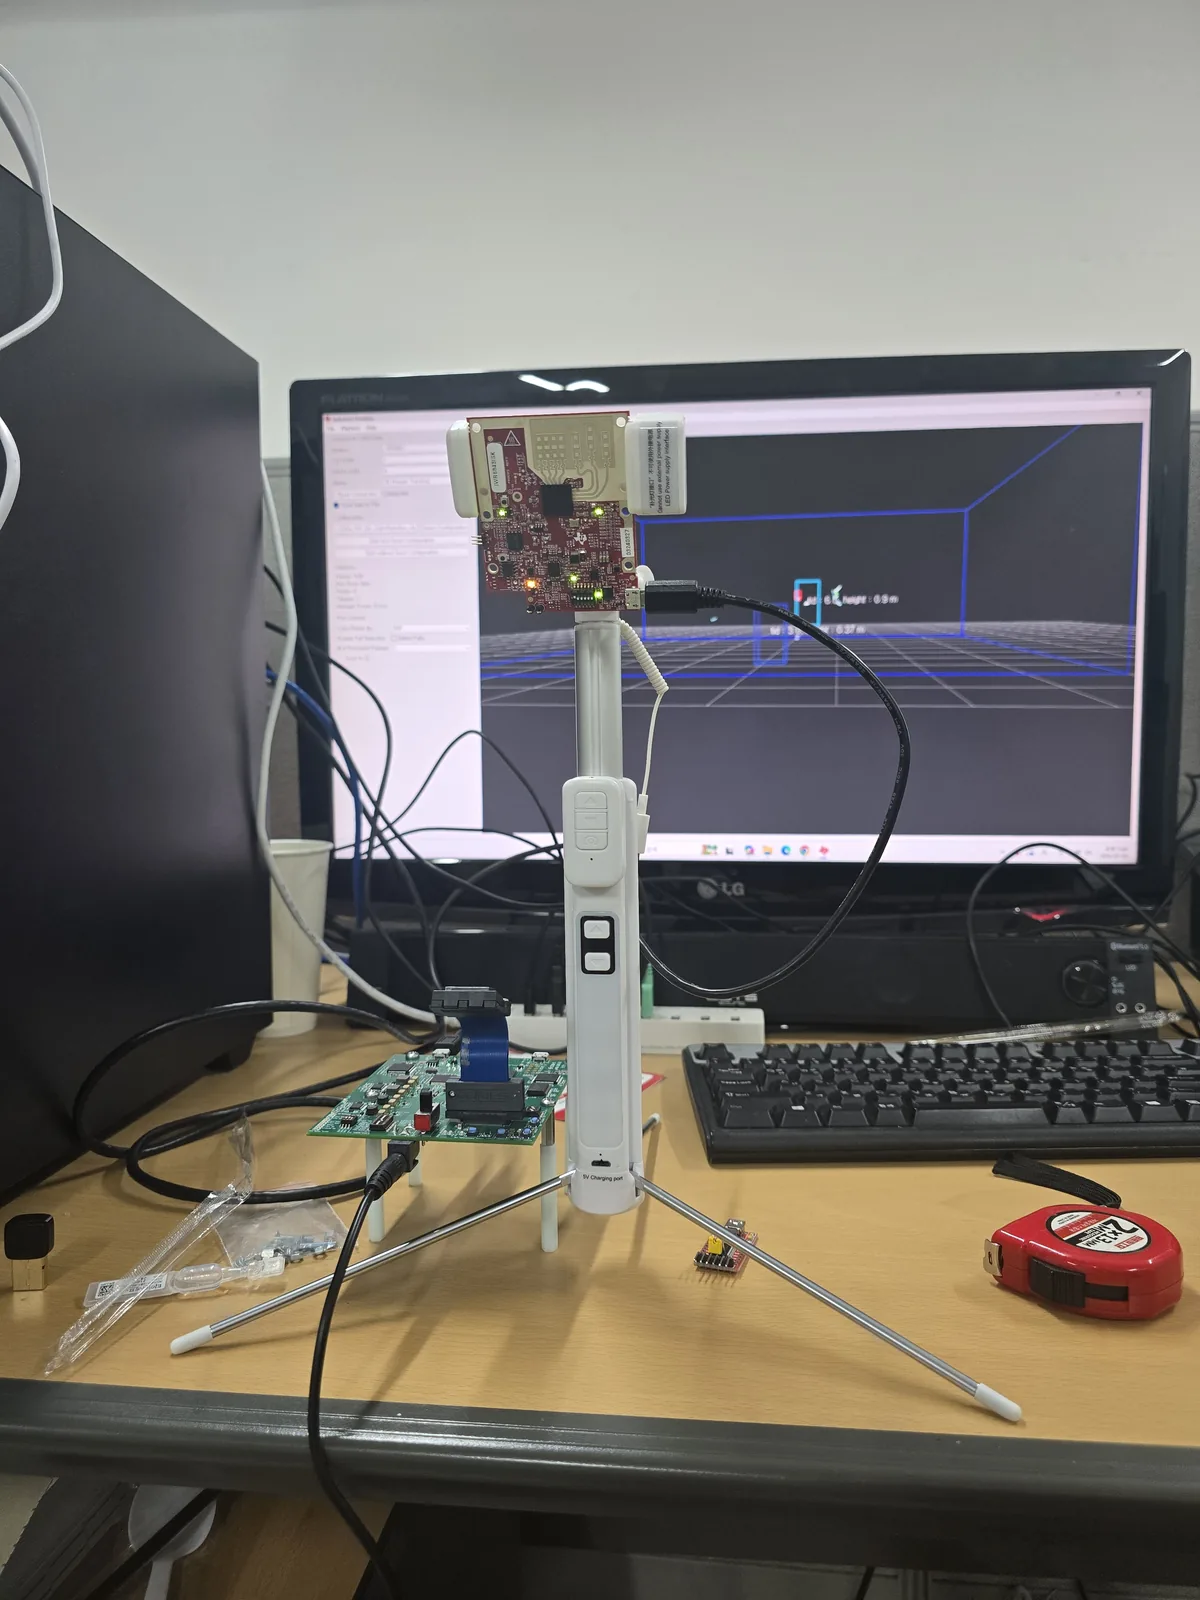
IWR6843 · DSS, UART, Visualizer
01
The task was to trace how configuration values propagate to 3D tracking output across radar algorithms, a DSP build, serial links, and a GUI.
02
IWR6843 sensor → range/Doppler processing with 2D Capon/MVDR and CFAR → DSS/MSS shared memory and mailbox → dual UART → Visualizer.
03
04
Radar chirps → range, Doppler, and angle processing → dynamic/static CFAR → point cloud and target list → serial packet → 3D display.
05
06
Software base: TI Radar Toolbox and SDK examples. Scope: configuration, DSS build structure, communication, and GUI. MSS artifact: binary. Vital-sign view: functional display.
The IWR6843 setup uses sensor height, orientation, FOV, range, and threshold settings matched to the room. C674x DSS processing and DSS–MSS transfer feed the 115200-bps CLI and 921600-bps data UART paths, ending in 3D point-cloud and target-tracking views.
Software base: TI Radar Toolbox and SDK examples. Archived artifacts: DSS build records, MSS binary, and Visualizer screens.